Description
Product Overview
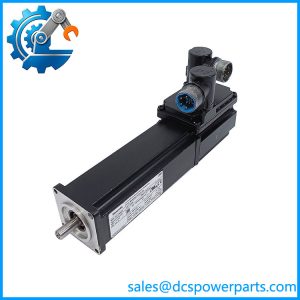
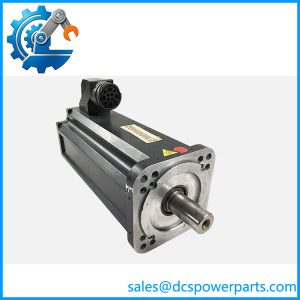
The Bosch Rexroth MSK030C-0900-NN-M1-UG0-NNNN is an IndraDyn S synchronous servo motor designed for precision motion control in industrial machinery. Its compact MSK030 frame and 9,000 rpm maximum speed make it suitable for applications requiring controlled acceleration, repeatable positioning, and high rotational speed. The motor operates as part of a servo axis, receiving power and motion commands from a compatible drive while its encoder provides position feedback to the control system.
This configuration uses an M1 multiturn absolute encoder with Hiperface interface and a plain shaft with shaft seal ring. The UG0 designation identifies the version without a holding brake. Natural convection cooling eliminates the need for a separate motor fan in the standard configuration, while the IP65 housing rating provides protection against dust ingress and water jets under the specified test conditions. Published data identifies a continuous standstill torque of 0.8 Nm and a maximum torque of 4.0 Nm. The motor’s maximum speed is 9,000 rpm.
For maintenance engineers, the Bosch Rexroth MSK030C-0900-NN-M1-UG0-NNNN is a replacement option for machinery originally designed around this exact motor configuration. The encoder interface, shaft construction, absence of a holding brake, and electrical motor data must all match the installed system. Bosch Rexroth documentation identifies HCS 01.1E-W0005 and HCS 01.1E-W0008 as recommended controller combinations for the MSK030C-0900 motor. Actual drive suitability still depends on the machine’s supply, current requirements, firmware, and configured motor data.
Product Introduction (Non-Templated)
When a compact servo axis must maintain positioning accuracy at high rotational speed, motor feedback and mechanical configuration are just as important as torque capacity. The MSK030C-0900 combines a multiturn absolute Hiperface encoder with a plain shaft and natural convection cooling.
This specific UG0 version has no holding brake. Replacing it with a brake-equipped motor requires a separate review of the drive, wiring, and machine safety design.
Key Technical Specifications
| Parameter | Specification |
|---|---|
| Product Model | MSK030C-0900-NN-M1-UG0-NNNN |
| Bosch Rexroth Order Number | R911308683 |
| Manufacturer | Bosch Rexroth |
| Product Family | IndraDyn S MSK |
| Motor Type | Synchronous servo motor |
| Motor Size | 030 |
| Motor Length | C |
| Winding Code | 0900 |
| Maximum Speed | 9,000 rpm |
| Continuous Standstill Torque (60 K) | 0.8 Nm |
| Maximum Torque | 4.0 Nm |
| Continuous Standstill Current (60 K) | 1.5 A |
| Maximum Current | 6.8 A |
| Torque Constant at 20°C | 0.58 Nm/A |
| Winding Inductivity | 14.1 mH |
| Encoder Type | Multiturn absolute |
| Encoder Interface | Hiperface |
| Encoder Resolution | 128 signal periods |
| Holding Brake | None |
| Shaft Design | Plain shaft with shaft seal ring |
| Cooling | Natural convection |
| Protection Rating | IP65 |
| Operating Ambient Temperature | 0–40°C |
| Weight | Approximately 1.9 kg |
Specifications are based on available MSK030C and exact order-code references. Confirm nameplate data and the applicable motor documentation before final drive sizing.
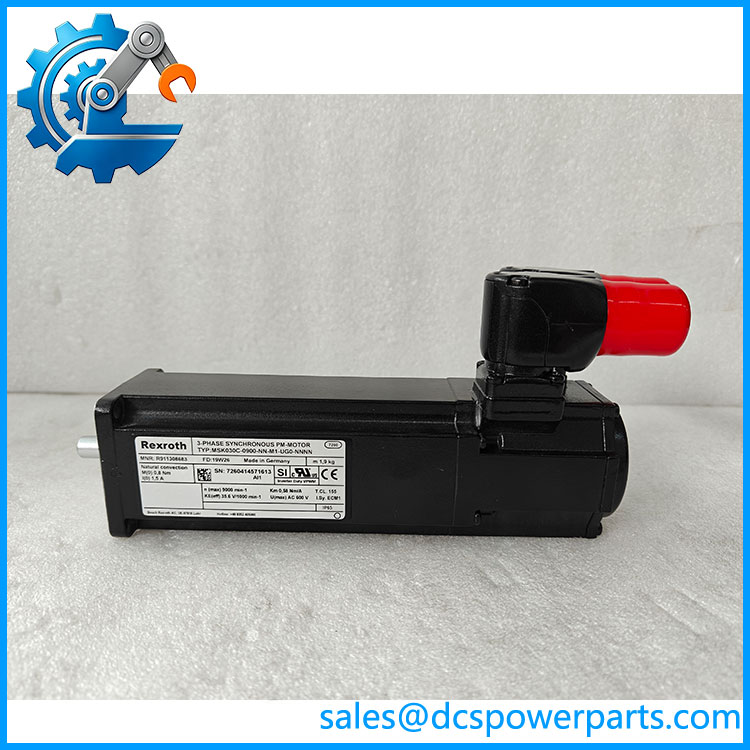
MSK030C-0900-NN-M1-UG0-NNNN
Related Products
The following are related Bosch Rexroth IndraDyn S motor references. They are not automatic substitutes for the configuration.
- R911308684 – -0900-NN-M1-UG1-NNNN: Similar motor configuration with holding brake.
- R911306060 – MSK040C-0600-NN-M1-UG0-NNNN: MSK040C motor without holding brake.
- R911306061 – MSK040C-0600-NN-M1-UG1-NNNN: MSK040C version with holding brake.
- R911298354 – MSK050C-0600-NN-M1-UG0-NNNN: MSK050C motor without holding brake.
- R911298355 – MSK050C-0600-NN-M1-UG1-NNNN: MSK050C version with holding brake.
- R911306052 – MSK060C-0600-NN-M1-UG0-NNNN: MSK060C motor without holding brake.
- R911306053 – MSK060C-0600-NN-M1-UG1-NNNN: MSK060C version with holding brake.
These models appear in Bosch Rexroth motor selection documentation. Verify frame size, winding, encoder, brake, and drive compatibility before considering any substitution.
Frequently Asked Questions
Q1: What is the Boroth -NN-M1- used for?
It is a synchronous servo motor for industrial motion-control axes. Typical applications include automated machinery requiring controlled speed, positioning, and coordinated movement.
Q the -NN-M1- include a holding brake?
No. The UG0 configuration is the version without a holding brake. The related UG1 configuration is listed with a holding brake, but it should not be substituted without checking the machine’s mechanical and electrical requirements.
Q3: Can I hot-swap this servo motor while the machine is running?
Do not remove or install the motor while the servo drive is energized. Follow the machine’s isolation procedure, wait for the drive DC bus to discharge, and secure any suspended or gravity-loaded axis before mechanical work.
Q4: Which encoder does this motor use?
It uses an M1 multiturn absolute encoder with a Hiperface interface. Confirm the feedback connection and drive support before commissioning.
Q5: Which servo drives are compatible with this motor?
Bosch Rexroth selection documentation lists HCS 01.1E-W0005 and HCS 01.1E-W0008 as recommended controller combinati the . Verify the complete drive configuration and motor data before installation.
Q6: Does this motor support firmware v3.1?
Firmware compatibility is determined by the connected servo drive and control system. The motor itself does not run application firmware. Check the drive’s firmware version, motor database, and encoder support.
Q7: What should I verify before purchasing a replacement?
Check the complete model code and order number R911308683. Confirm the plain shaft, M1 Hiperface encoder, absence of holding brake, connector orientation, mounting dimensions, and motor condition. For used stock, request insulation, winding, encoder, and mechanical inspection results.
Procurement note: The most important replacement distinction is UG0 versus UG1: this model has no holding brake. Do not accept a brake-equipped version as equivalent without reviewing the machine’s safety and control design.