Description
Product Overview
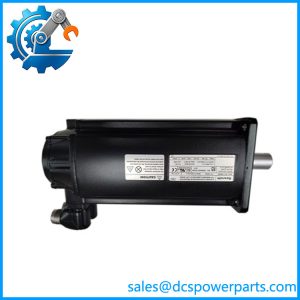
The Bosch Rexroth MHD093C-058-PG1-AA is a permanent-magnet synchronous servo motor from the Indramat MHD motor family. The exact motor reference is also associated with R911287231. Available technical records identify a 23.0 Nm continuous torque at standstill, a 6000 RPM maximum speed, natural-convection cooling, IP65 protection, and insulation class F. ([turn0search0]) This makes the motor suitable for machine axes where controlled acceleration, positioning, and feedback-based speed regulation are required.
For Bosch Rexroth MHD093C-058-PG1-AA, the mechanical configuration is particularly important. The motor uses a 140/150 mm flange size, 130 mm centering diameter, a plain shaft with shaft seal, and power connection toward side A. ([turn0search0]) It incorporates a digital servo feedback system with an integrated encoder capable of absolute position detection over more than 4096 revolutions. ([turn0search2]) The 058 portion of the type code identifies the winding configuration and should be matched with the drive’s motor data rather than treated as a cosmetic suffix.
The Bosch Rexroth MHD093C-058-PG1-AA also includes a 22 Nm holding brake, according to the stronger technical references. ([turn0search0]turn0search8) That brake is intended for holding the axis when the motor is not producing torque; it should not be treated as a dynamic stopping device unless the machine documentation explicitly permits that operating mode. In a legacy Indramat installation, the practical replacement checks are motor winding, encoder/feedback interface, brake voltage, shaft and flange dimensions, drive parameters, and cable pinout. A physically identical MHD motor can still be unsuitable if the drive configuration does not match.
Product Introduction
A replacement servo motor can fit the machine mechanically and still fail at commissioning if the feedback or winding configuration differs. Bosch Rexroth MHD093C-058-PG1-AA combines 23 Nm standstill torque, 6000 RPM maximum speed, integrated absolute feedback, and a holding brake in one MHD-series motor. ([turn0search0])
For a legacy Indramat servo motor replacement, the 058 winding code, encoder configuration, brake circuit, flange, shaft, and mating drive should be checked as one system. The motor weighs approximately 23.5 kg and carries an IP65 enclosure rating. ([turn0search0])
Key Technical Specifications
| Parameter | Value |
|---|---|
| Manufacturer | Bosch Rexroth / Indramat |
| Model | MHD093C-058-PG1-AA |
| OEM Reference | R911287231 |
| Product Family | MHD Synchronous Motors |
| Product Type | Permanent-Magnet Synchronous Servo Motor |
| Motor Size | MHD093C |
| Winding Code | 058 |
| Motor Length | C |
| Continuous Torque at Standstill | 23.0 Nm |
| Maximum Speed | 6000 RPM |
| Holding Brake | Yes |
| Holding Brake Torque | 22.0 Nm |
| Feedback | Digital servo feedback with integrated encoder |
| Position Detection | Absolute, >4096 revolutions |
| Flange Size | 140/150 mm |
| Centering Diameter | 130 mm |
| Shaft | Plain shaft |
| Shaft Seal | Yes |
| Cooling | Natural convection |
| Insulation Class | F |
| Protection Rating | IP65 |
| Power Connection | Side A |
| Weight | Approx. 23.5 kg |
The motor’s torque, speed, brake, feedback, flange, centering diameter, IP rating, insulation class, and weight are supported by available MHD093C-058-PG1-AA technical records.
Important: Some secondary listings give conflicting brake torque and rated-torque figures. For this exact motor, the more consistent technical records identify 22.0 Nm holding-brake torque and 23.0 Nm continuous torque at standstill.
Related Products
- MHD093B Series — Smaller MHD frame configuration. It can suit lower-power axes but is not a drop-in replacement for the .
- MHD095C Series — Larger related MHD motor family. It may provide different torque characteristics and mounting dimensions.
- MKD041B-144-KG0-KN — Related Indramat synchronous motor with a substantially smaller torque rating. It is suited to smaller servo axes rather than replacing the .
- MKD041B-144-KP1-KN — Another Indramat synchronous motor configuration. Its feedback, brake, shaft, and torque specifications differ, so application matching is required.
- Indramat MHD Servo Drives — The corresponding drive family for MHD motors. Motor winding and feedback data must be entered or configured correctly in the drive.
- Rexroth Indramat Digital Servo Controllers — Compatible drive/controller hardware used to regulate MHD-series motors. Exact compatibility depends on motor current, feedback, and application parameters.
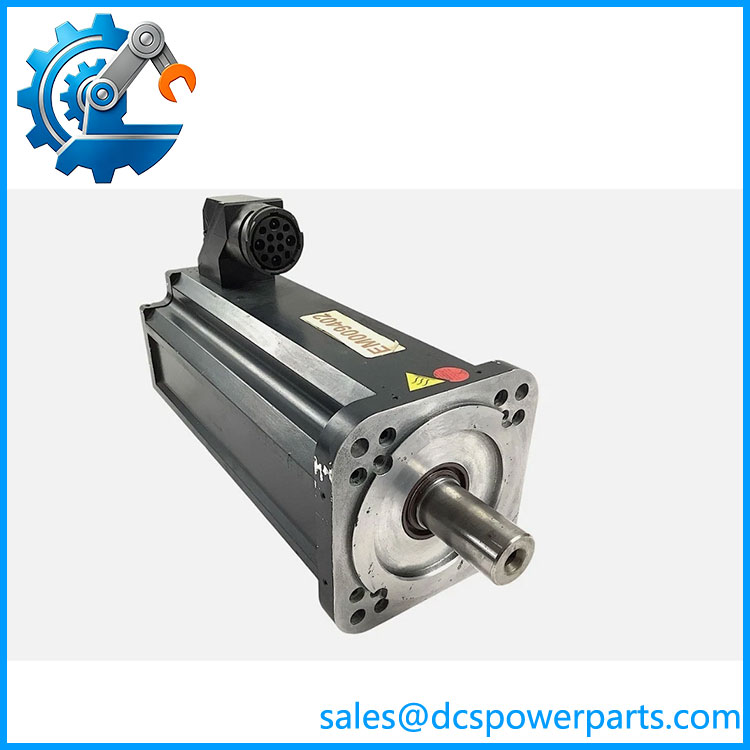
MHD093C-058-PG1-AA
Frequently Asked Questions
Whatch Rexroth used for?
The is a permanent-magnet synchronous servo motor designed for closed-loop industrial motion control.
Its integrated digital feedback allows the servo drive to determine motor position and speed, while the holding brake can secure the axis when the motor is de-energized. The motor is specified for up to 6000 RPM and 23.0 Nm continuous torque at standstill.
What is the OEnumber for ?
The motor is associated with R911287231 in available product records.
For procurement, I recommend recording both identifiers:
R911287231
That reduces the chance of receiving another MHD motor with a similar housing but a different winding or feedback configuration.
What does 8” mean in ?
The 058 identifies the motor’s winding code.
This is not a harmless catalog suffix. The winding configuration affects the electrical relationship between the motor and servo amplifier. When replacing the motor, the drive’s configured motor data should therefore be checked against the complete MHD nameplate.
I replace with anot093C motor?
Not based on the frame size alone.
Compare:
- Winding code.
- Feedback type.
- Holding-brake configuration.
- Brake voltage.
- Continuous and peak torque.
- Maximum speed.
- Flange and shaft dimensions.
- Drive compatibility.
- Motor cable and connector pinout.
The family contains multiple configurations. A motor with the same physical frame can have a different electrical configuration.
Ct-swap the ?
No.
This is a motor connected to a servo amplifier and a mechanical load. The drive must be disabled and isolated before disconnecting motor power or feedback wiring.
The holding brake also deserves attention. Do not release the brake until the axis is mechanically secured and the machine’s maintenance procedure confirms that releasing it is safe.
Will replacing the motor erase my PLC or CNC logic?
Normally, replacing the physical motor does not erase the controller application.
The main issue is servo configuration. Depending on the drive architecture, motor-specific parameters may include:
- Motor identification
- Winding data
- Feedback configuration
- Current limits
- Torque scaling
- Brake control
- Commutation data
- Encoder settings
After installation, the axis should be referenced and tested at controlled speed before returning it to automatic operation.
Does support firmware v3.1?
Firmware v3.1 is not a sufficient compatibility criterion for this motor.
The is a motor rather than a programmable PLC/DCS module. Compatibility depends primarily on the servo amplifier, motor winding code, feedback system, brake configuration, and drive parameter set.
If a drive replacement is also involved, then its firmware revision becomes a separate compatibility check.
How should I verew Surplus ?
For a high-value servo motor, visual inspection alone is not enough.
Recommended acceptance checks:
- Confirm complete nameplate.
- Confirm OEM reference
R911287231. - Verify winding code
058. - Inspect shaft and shaft seal.
- Check flange and centering diameter.
- Test brake operation and brake resistance.
- Check encoder/feedback communication.
- Measure winding resistance phase-to-phase.
- Check insulation resistance using the appropriate procedure.
- Inspect bearings for abnormal noise or play.
- Verify motor rotation under controlled conditions.
- Record test results and serial number.
The motor’s integrated absolute encoder is particularly important. Available documentation identifies absolute position detection over more than 4096 revolutions, so a basic continuity test on the feedback connector does not prove that the encoder is functioning correctly.