Description
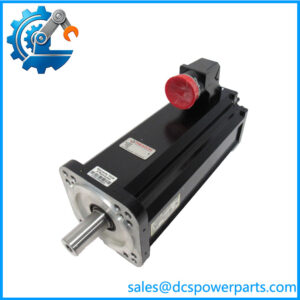
Bosch Rexroth MSK060C-0600-NN-S1-UP1-NNNN | IndraDyn S Servo Motor | R911306055
Key Technical Specifications
| Parameter | Specification |
|---|---|
| Manufacturer | Bosch Rexroth |
| Series | IndraDyn S |
| Model | MSK060C-0600-NN-S1-UP1-NNNN |
| Material Number | R911306055 |
| Motor Size | MSK060 |
| Motor Length | C |
| Winding / Speed Code | 0600 |
| Cooling | Natural convection |
| Encoder | Optical singleturn Hiperface |
| Encoder Resolution | 128 signal periods |
| Encoder Connector | Rotatable, 240° |
| Shaft | Keyway, DIN 6885-1 |
| Holding Brake | Electrically released |
| Brake Torque | 10 Nm |
| Brake Rated Voltage | 24 V |
| Brake Rated Current | 0.25 A |
| Continuous Torque at Standstill | 8.8 Nm |
| Continuous Current at Standstill | 10.5 A |
| Maximum Torque | 24 Nm |
| Maximum Current | 38 A |
| Winding Inductivity | 8.6 mH |
The published configuration data identifies the motor as naturally cooled and equipped with the S1 singleturn Hiperface encoder, keyed shaft, and 10 Nm brake. Secondary technical data lists 8.8 Nm continuous standstill torque, 24 Nm maximum torque, 10.5 A standstill current, and 38 A maximum current.
Product Introduction
The Bosch Rexroth MSK060C-0600-NN-S1-UP1-NNNN is an IndraDyn S synchronous servomotor intended for closed-loop motion applications where the drive requires encoder feedback for position and speed control. Its configuration combines natural-convection cooling, a singleturn Hiperface encoder, keyed shaft, and electrically released 10 Nm holding brake. The documented Bosch Rexroth material number is R911306055.
The motor belongs to the MSK060 family used in machine tools, packaging, robotics, paper processing, and other dynamic motion systems. For replacement work, the complete type code matters: encoder technology, shaft configuration, connector orientation, and brake selection are part of the motor’s application compatibility.
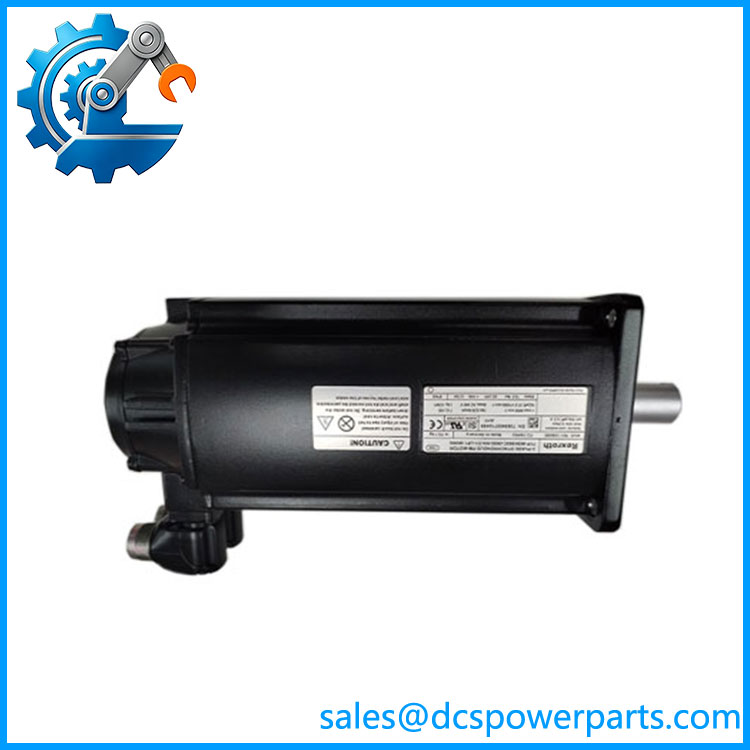
MSK060C-0600-NN-S1-UP1-NNNN
Application Scenarios & Field Pitfalls — The Engineer’s Perspective
Engineering Pain Point
A servo motor replacement can look correct mechanically and still fail during commissioning. With the MSK series, the drive does not simply need a motor with the same frame size. The encoder type, motor data, brake configuration, shaft arrangement, and drive parameterization all have to match the machine’s original configuration.
Typical Applications
- CNC machine axes and machine-tool motion
- Packaging and converting machinery
- Printing and paper-processing equipment
- Robotic and automated positioning systems
- General industrial servo axes
- Linear modules using MSK-series servo motors
Bosch Rexroth documentation lists MSK060 motors among the motor options used with linear modules, while the broader IndraDyn S family is intended for dynamic machine applications.
Technical Pitfalls
- Match the complete type code.
MSK060B and MSK060C are not simply cosmetic length variants. The winding/speed code and motor characteristics must be checked against the drive configuration. - S1 is not M1.
This motor uses an optical singleturn Hiperface encoder with 128 signal periods. M1 denotes an optical multiturn absolute Hiperface encoder. Substituting an M1 motor for an S1 motor can affect drive configuration and machine homing behavior. - The brake is part of the specified configuration.
The UP1 designation corresponds to a 10 Nm electrically released holding brake. A motor without the brake is not an equivalent replacement for an axis that depends on mechanical holding. - Check the shaft.
The P shaft designation specifies a keyed shaft according to DIN 6885-1. Do not substitute a plain-shaft version without checking the coupling or pulley arrangement. - Encoder feedback must be verified before power-up.
Incorrect encoder selection or parameterization can produce feedback faults, incorrect commutation, or unexpected axis behavior. The drive’s stored motor data should be compared with the replacement motor’s nameplate and type code. - Brake wiring requires separate attention.
The holding brake is electrically released. The motor should therefore be checked for the correct brake supply and release logic before attempting servo operation. Published data identifies the brake as 24 V, 0.25 A, with 10 Nm holding torque. - Do not use maximum torque as continuous operating torque.
The published figures distinguish 8.8 Nm continuous torque at standstill from 24 Nm maximum torque. Actual continuous torque depends on operating speed, temperature, drive configuration, and the applicable motor characteristic curve.
Related Products
- MSK060C-0600-NN-M1-UG1-NNNN — Related MSK060C configuration using a multiturn Hiperface encoder; not a direct encoder-equivalent substitute.
- MSK060C-0600-NN-M1-UG0-NNNN — Similar motor configuration without the holding brake.
- -0600-NN-S1-UP0-NNNN — S1 encoder and keyed-shaft configuration without the 10 Nm holding brake.
- MSK060C-0600-NN-S1-UP1-NNNN — Exact specified motor configuration.
- MSK060B-0600 — Same MSK060 family with the B-length motor configuration; verify torque and mechanical requirements before substitution.
- MSK050C-0600 — Smaller MSK family motor; not an automatic mechanical or electrical replacement.
- MSK076C-0450 — Larger MSK family motor with different frame and rated-speed characteristics.
- IndraDrive drive controllers — The compatible drive must be checked against the motor’s encoder, winding, current, and motor parameter data.
Procurement Note
For a replacement, specify the complete code MSK060C-0600-NN-S1-UP1-NNNN and R911306055, not merely “MSK060 servo motor.” The most important verification points are the S1 Hiperface singleturn encoder, 240° rotatable connector, keyed shaft, 10 Nm electrically released brake, and motor length C. Bosch Rexroth’s type-code documentation should take precedence over generic MSK060 listings when evaluating interchangeability.
For a used or refurbished motor, inspect the encoder connector, shaft/keyway, brake operation, bearings, winding insulation, and nameplate before installation. If the original drive remains in service, compare its configured motor data against R911306055 before enabling the axis.