Description
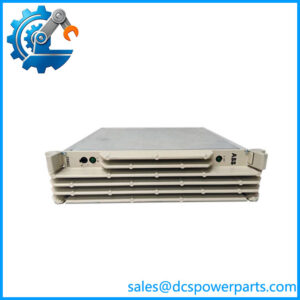
ABB ACU-01B 3HNA024871-001
Product Introduction
In an ABB paint-robot system, an air-control fault can stop the coating process even when the robot controller and mechanical axes remain available. The ABB ACU-01B 3HNA024871-001 is identified as an ACU-01B spare for ABB paint-robot applications and forms part of the air-control and communication architecture. ABB’s technical note specifically addresses ACU-01B communication configuration, making the unit a configuration-sensitive spare rather than a generic pneumatic replacement.
The main issue during replacement is not simply matching the label. ABB documents that paint robots delivered from September 2019 use Ethernet mode, while ACU-01B spares may be supplied in CAN mode; the communication mode must therefore be checked before commissioning. ABB states that CAN and Ethernet IPS nodes cannot simply be mixed within the same IPS communication arrangement.
Key Technical Specifications
| Parameter | Specification |
|---|---|
| Product Model | ACU-01B |
| ABB Part Number | 3HNA024871-001 |
| Manufacturer | ABB Robotics |
| Product Type | Air Control Unit |
| Primary Application | ABB paint-robot systems |
| System Function | Air-control and associated robot-system communication |
| Communication Modes | CAN / Ethernet, configuration dependent |
| Configuration Concern | Installed communication architecture must match |
| Relevant Software | IPS software environment; ABB documentation specifies applicable versions |
| Console Configuration | Terminal access documented at 115200 baud |
| Installation | ABB paint-robot system-specific |
| Replacement Verification | Complete part number, configuration, serial number and system architecture |
| Net Weight | 3.06 kg according to ABB’s current spare-parts page |
| Condition | Verify actual inventory condition before purchase |
ABB’s technical note states that an spare supplied in CAN mode is not compatible with paint-robot systems requiring Ethernet mode without changing the communication mode. The documented configuration procedure uses the console port at 115200 baud. ABB’s current spare-parts page lists a net weight of 3.06 kg, although that same page currently displays SxTPU3 information that does not correspond cleanly with the technical note; this should be treated as a catalog-data inconsistency rather than a reason to assume the part is a teach-pendant board.
Major Features / Advantages
1. Dedicated ABB Paint-Robot Spare
The is not best treated as a generic air-control component. ABB maintains a dedicated technical note covering its use as a spare part and, critically, its CAN-versus-Ethernet operating configuration. That makes the exact ABB material number important during procurement. A visually similar controller or pneumatic assembly does not establish functional equivalence.
2. CAN/Ethernet Configuration Matters
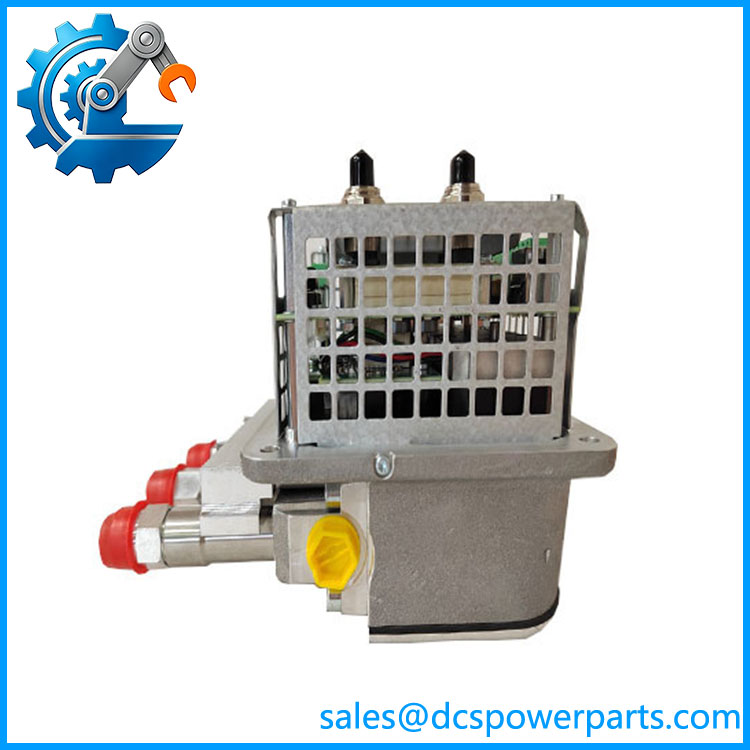
ACU-01B 3HNA024871-001
This is the specification that deserves the most attention during replacement. ABB states that paint robots delivered from September 2019 are installed with Ethernet mode, while an spare may be delivered with CAN mode. If the replacement remains in the wrong mode, it will not communicate correctly with the affected robot system.
For maintenance planning, record the communication architecture before removing the failed unit. Do not assume that the communication setting will automatically follow the replacement hardware. ABB documents a console-based procedure for changing the to Ethernet mode, followed by a system restart.
3. Configuration-Specific Robot Integration
The belongs inside an ABB robotic painting architecture, so replacement should be evaluated against the complete installation rather than against the component name alone. The connected robot controller, IPS nodes, communication method, pneumatic arrangement, cabling, and software environment all matter.
This is especially relevant during legacy robot maintenance. A replacement can be electrically intact and still fail commissioning because its communication mode does not correspond with the existing system.
4. Useful for Planned Maintenance
Keeping an accurately identified spare can reduce troubleshooting time when an air-control or associated communication fault occurs. The practical benefit is not simply having another module on the shelf; it is having the correct configuration documented before the production outage.
Record the installed ACU serial number, communication mode, controller type, software environment, cable arrangement, and pneumatic connections as part of the maintenance record. That information becomes valuable when a replacement is needed months later.
5. Exact-Part Procurement Reduces Configuration Risk
The full 3HNA024871-001 article number should remain on the purchase order and inspection record. Do not shorten the identification to “” when purchasing a replacement. ABB’s own technical documentation demonstrates that configuration differences can affect compatibility.
There is also an unusual documentation issue worth flagging: ABB’s present web page associates the same material number with SxTPU3/DSQC679 information, while ABB separately lists SxTPU3 under 3HAC028357-001. For procurement, the physical nameplate and complete ABB material number should therefore take priority over a generic web-page description.
Application Scenarios & Pain Points
Automotive Paint Lines
ABB paint robots operate in production environments where an air-control problem can affect coating quality or stop the spraying process. The is relevant where the documented ABB paint-robot architecture calls for this specific spare.
Legacy ABB Paint-Robot Maintenance
When an older robot remains in production because replacement would require significant mechanical and process requalification, maintaining the correct spare can be part of a practical lifecycle strategy. The key is preserving the existing communication and pneumatic configuration.
CAN-to-Ethernet Migration
This is one of the most important -specific scenarios. ABB’s technical note explicitly addresses systems delivered from September 2019 and the transition to Ethernet mode.
Emergency Replacement
Before installing an emergency spare, compare the replacement’s configuration with the failed unit. If the robot network uses Ethernet but the spare is configured for CAN, simply plugging it in may not restore communication. ABB documents a method for changing the communication mode through its console interface.
Engineer’s Guide — Field Pitfalls to Avoid
1. Do not treat CAN and Ethernet as interchangeable.
ABB explicitly states that IPS nodes cannot mix CAN and Ethernet communication within the same arrangement. Confirm the installed architecture first.
2. Do not purchase by model name alone.
Use + 3HNA024871-001 on the procurement documentation. Record the serial number and configuration where available.
3. Check the spare’s communication mode before the shutdown.
The replacement may arrive in CAN mode even though the installed robot requires Ethernet mode. ABB provides a documented configuration procedure through the console port.
4. Do not trust conflicting web descriptions without checking the physical part.
ABB’s current webpage contains SxTPU3/DSQC679 wording that conflicts with the dedicated technical note. ABB separately identifies SxTPU3 as 3HAC028357-001.
5. Verify the complete robot configuration.
Check controller generation, IPS communication arrangement, cabling, pneumatic connections, and software before commissioning.
6. Perform controlled functional testing after installation.
Restore electrical and pneumatic connections carefully, verify communication status, check alarms, and confirm air-control behavior before returning the paint robot to production.
Related Products & Components
- ABB — 3HNA024871-001: Exact spare identified in ABB’s technical documentation.
- ABB SxTPU3 — 3HAC028357-001: A separate ABB teach-pendant/main-board product. Do not confuse this material number with 3HNA024871-001 merely because ABB’s current ACU webpage displays SxTPU3 text.
- ABB 3HAC033596-002: SxTPU holder upper part referenced by ABB’s current spare-parts page; this is associated with the SxTPU3 documentation displayed on that page, not evidence that it is an accessory.
- ABB 3HAC033498-001 + 3HAC025352-001: New-holder part numbers listed on ABB’s current page in connection with its SxTPU3 information. Verify applicability before ordering against an installation.
FAQ
Is ABB 3HNA024871-001 an air control unit?
Yes. ABB’s dedicated technical note identifies the spare as and discusses its communication configuration for paint robots. Independent exact-part references also identify 3HNA024871-001 as an Air Control Unit.
Is 3HNA024871-001 the same as the SxTPU3 teach-pendant board?
The documentation needs careful handling here. ABB’s current webpage displays SxTPU3 text under 3HNA024871-001, but ABB’s separate SxTPU3 page identifies 3HAC028357-001 as the SxTPU3 product. ABB’s technical note independently identifies as the relevant spare for paint-robot communication architecture. I would therefore not substitute an SxTPU3 assembly for an based on the current webpage text alone.
Can an configured for CAN be used on an Ethernet paint robot?
Not without configuration changes. ABB specifically states that paint robots delivered from September 2019 use Ethernet mode and that an spare supplied in CAN mode will not be compatible without changing the mode.
How is the communication mode changed?
ABB’s technical note documents console-port access using a terminal program at 115200 baud, followed by the documented Ethernet-mode command and a restart. Configuration work should be performed only by personnel familiar with the applicable ABB robot service procedure.
Does the exact revision or serial number matter?
Yes. The complete article number should be matched, but the installed communication architecture and the replacement’s configuration also need to be checked. ABB even identifies a serial-number range for spares that are delivered with an automatic setup behavior.
What should procurement verify before buying 3HNA024871-001?
At minimum, verify the complete ABB part number, physical nameplate, serial number, communication mode, robot/controller configuration, software environment, connector and mounting arrangement, and actual inventory condition. If the supplier’s description conflicts with ABB documentation, request photographs of the nameplate and configuration details before accepting the unit.
What is the most important commissioning check?
Confirm communication first, then verify the air-control function and associated robot alarms under controlled conditions. A replacement that powers up is not necessarily a correctly configured replacement; the CAN/Ethernet distinction documented by ABB makes this particularly important for .